 Enrique del Sol – Robotics, Mechatronics & Control Research
Portfolio, Robotics Research Blog, Meeting Point & Showcase of Ideas
Friction behaviour
‹ Return to Dynamic modelling of robots with rigid links (I)
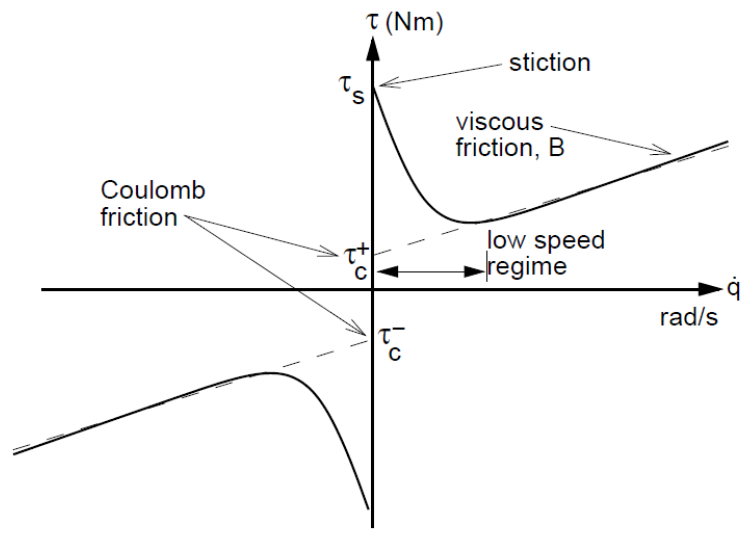
Friction behaviour
Share this:



Leave a Reply