 Enrique del Sol – Robotics, Mechatronics & Control Research
Portfolio, Robotics Research Blog, Meeting Point & Showcase of Ideas
closed loop robot
‹ Return to Dynamic modelling of robots: parameters identification (I)
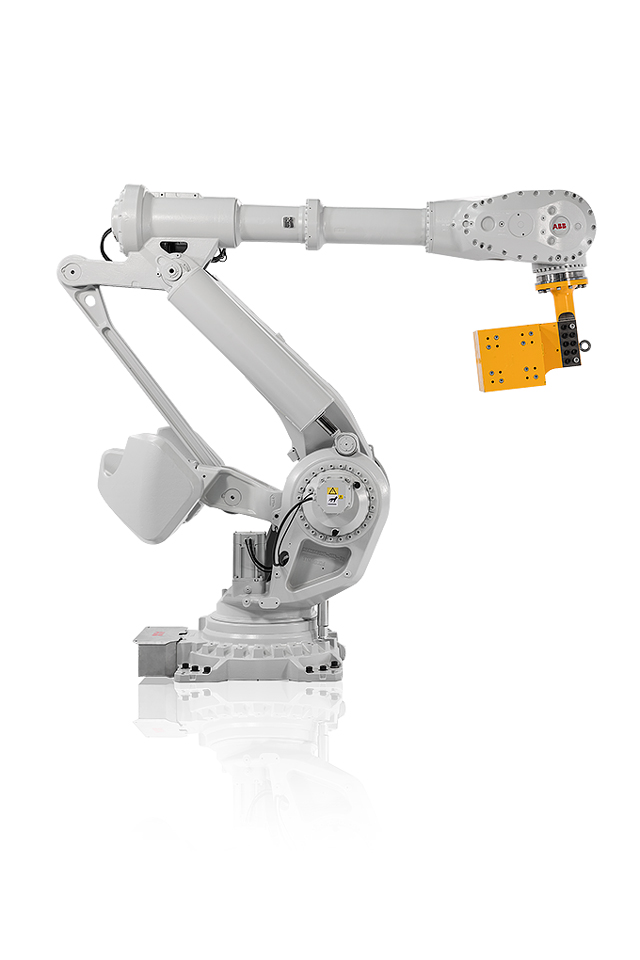
ABB robot with a closed loop.
Share this:



Leave a Reply