 Enrique del Sol – Robotics, Mechatronics & Control Research
Portfolio, Robotics Research Blog, Meeting Point & Showcase of Ideas
Kraft GRIPS
‹ Return to Dynamic modelling of robots with rigid links (II)
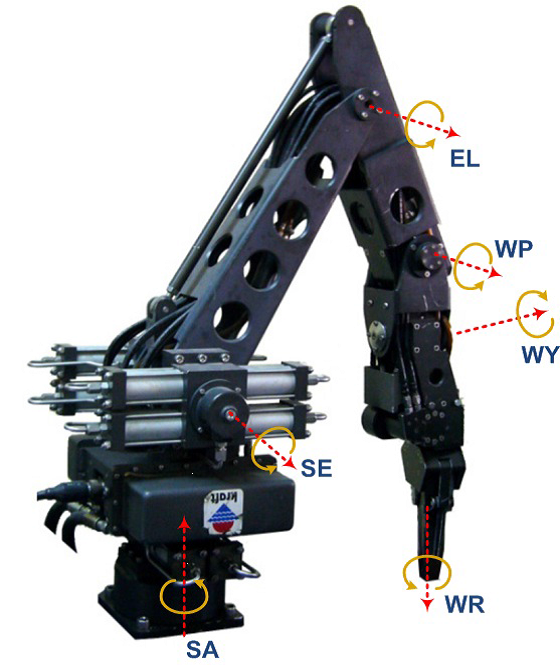
Kraft GRIPS hydraulic manipulator with force feedback
Share this:



Leave a comment